
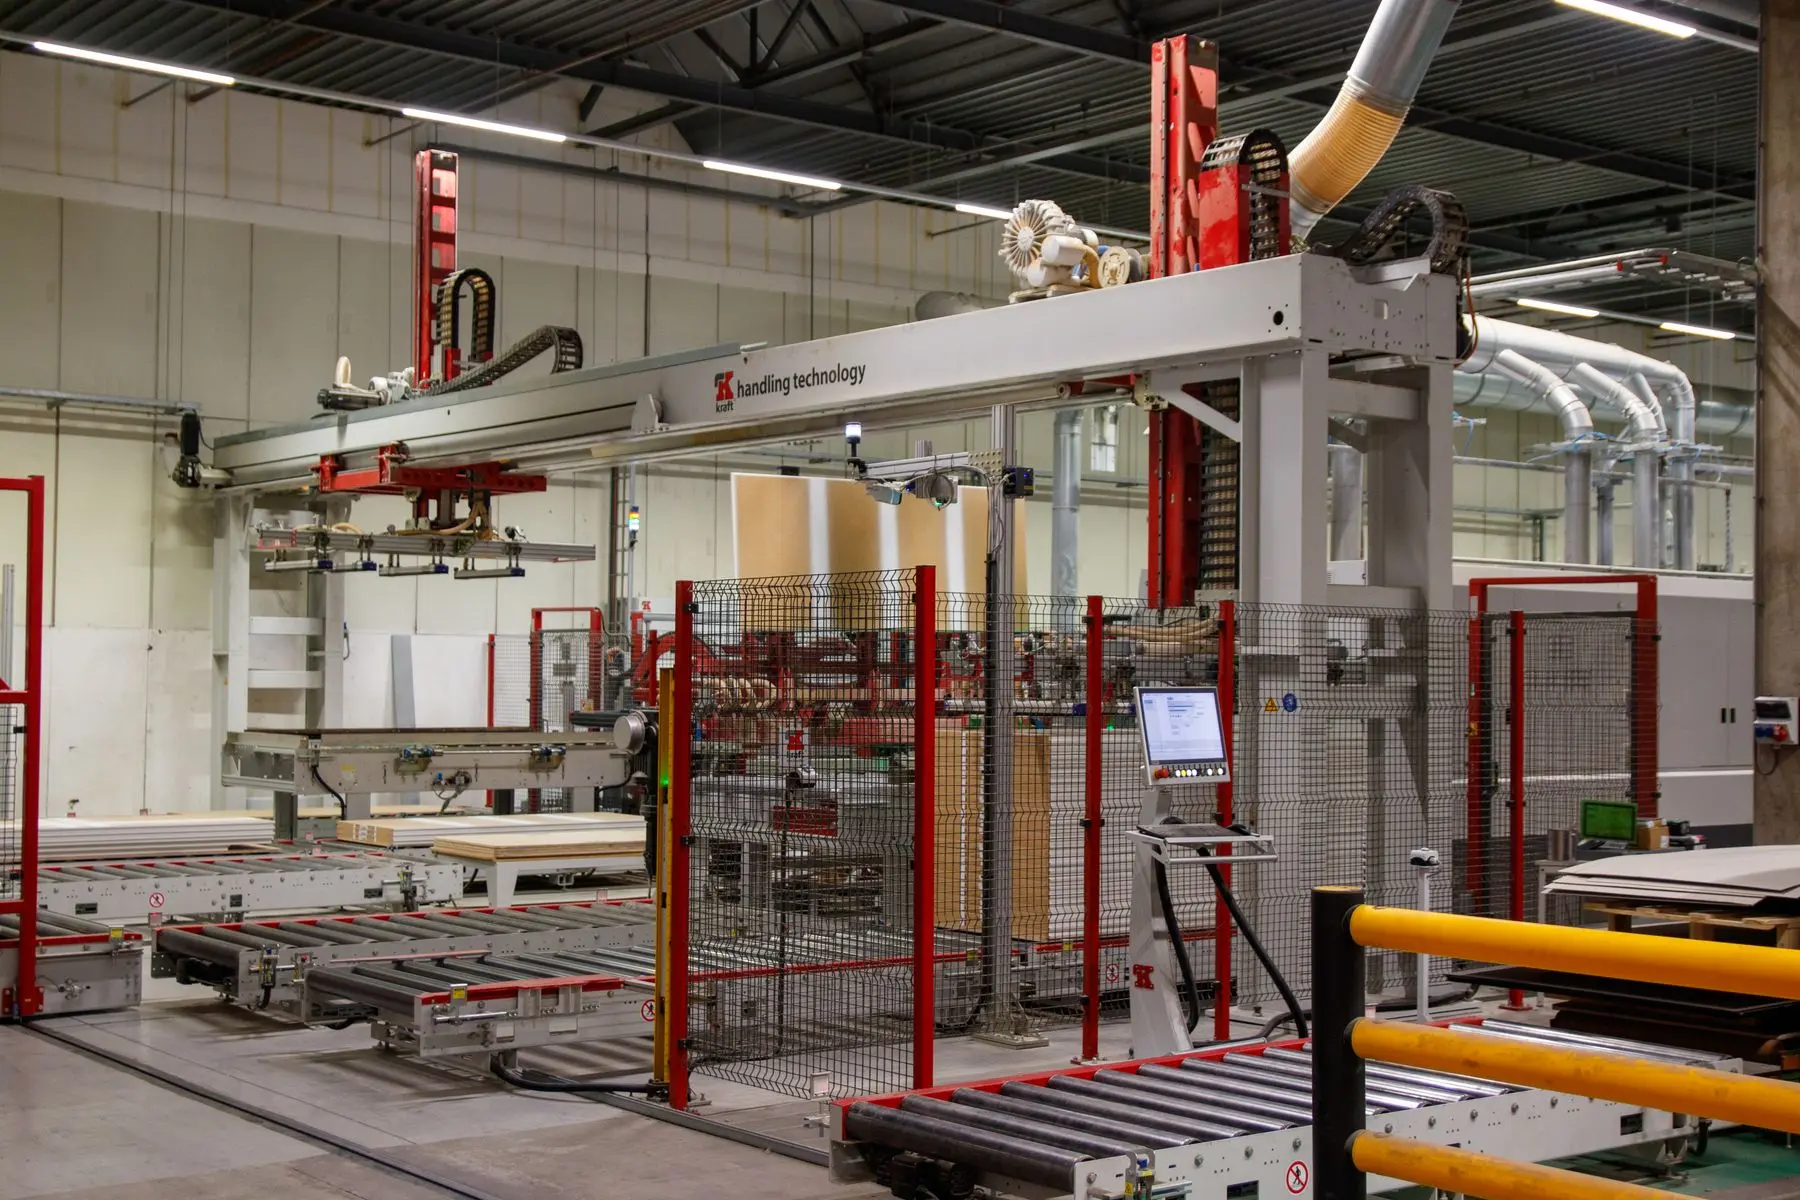
Column palletiser
65 kg long-reach platform
Representative option for high-layer palletising, depalletising and handling.
2,334 mmReach
65 kgPayload
±0.15 mmRepeatability
Robotic palletising systems for UK manufacturers
Reduce repetitive manual handling and create consistent pallets for boxes, bags, bottles, containers and other packaged products—with one partner from concept to production handover.
Robotic palletising applications
Different products need different ways of being presented, gripped, placed and supported. Explore the system most closely matched to your end-of-line process.
Cases, cartons, trays and shrink-wrapped packs.
Explore box systems
Sacks, valve bags and flexible filled packs.
Explore bag systems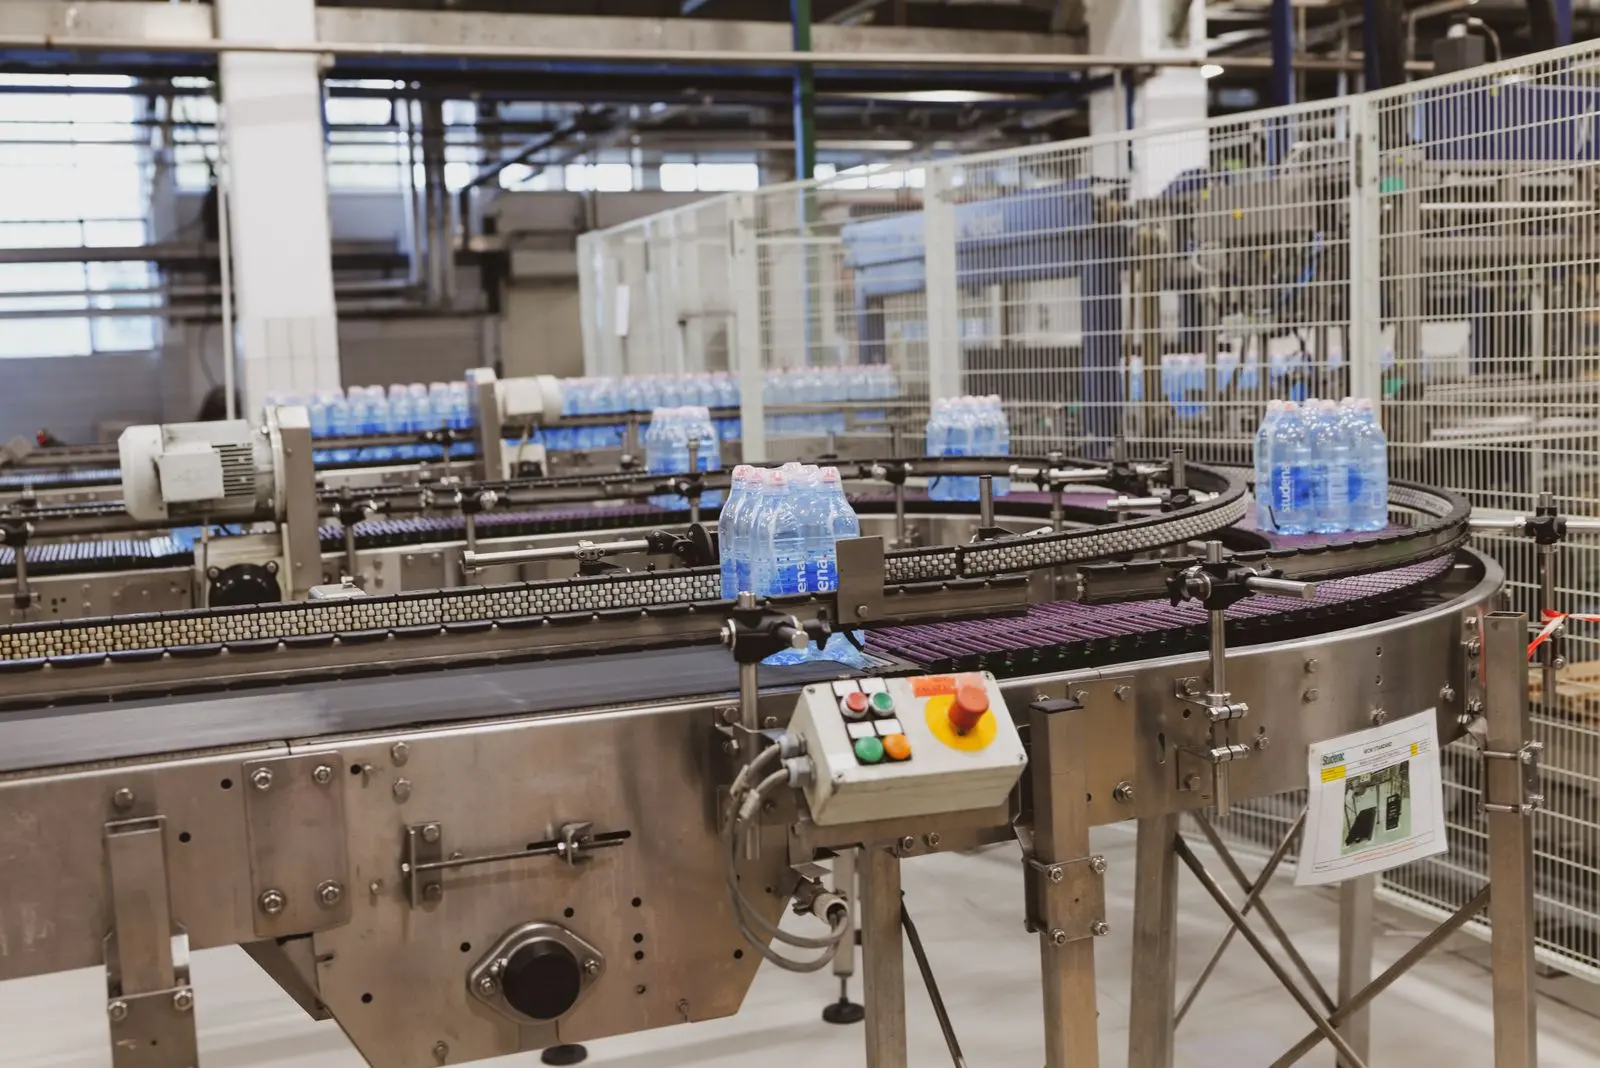
Bottles, cans, jars, trays and collations.
Explore bottle systems
Compact cells for suitable flexible, lower-rate applications.
Explore cobot cells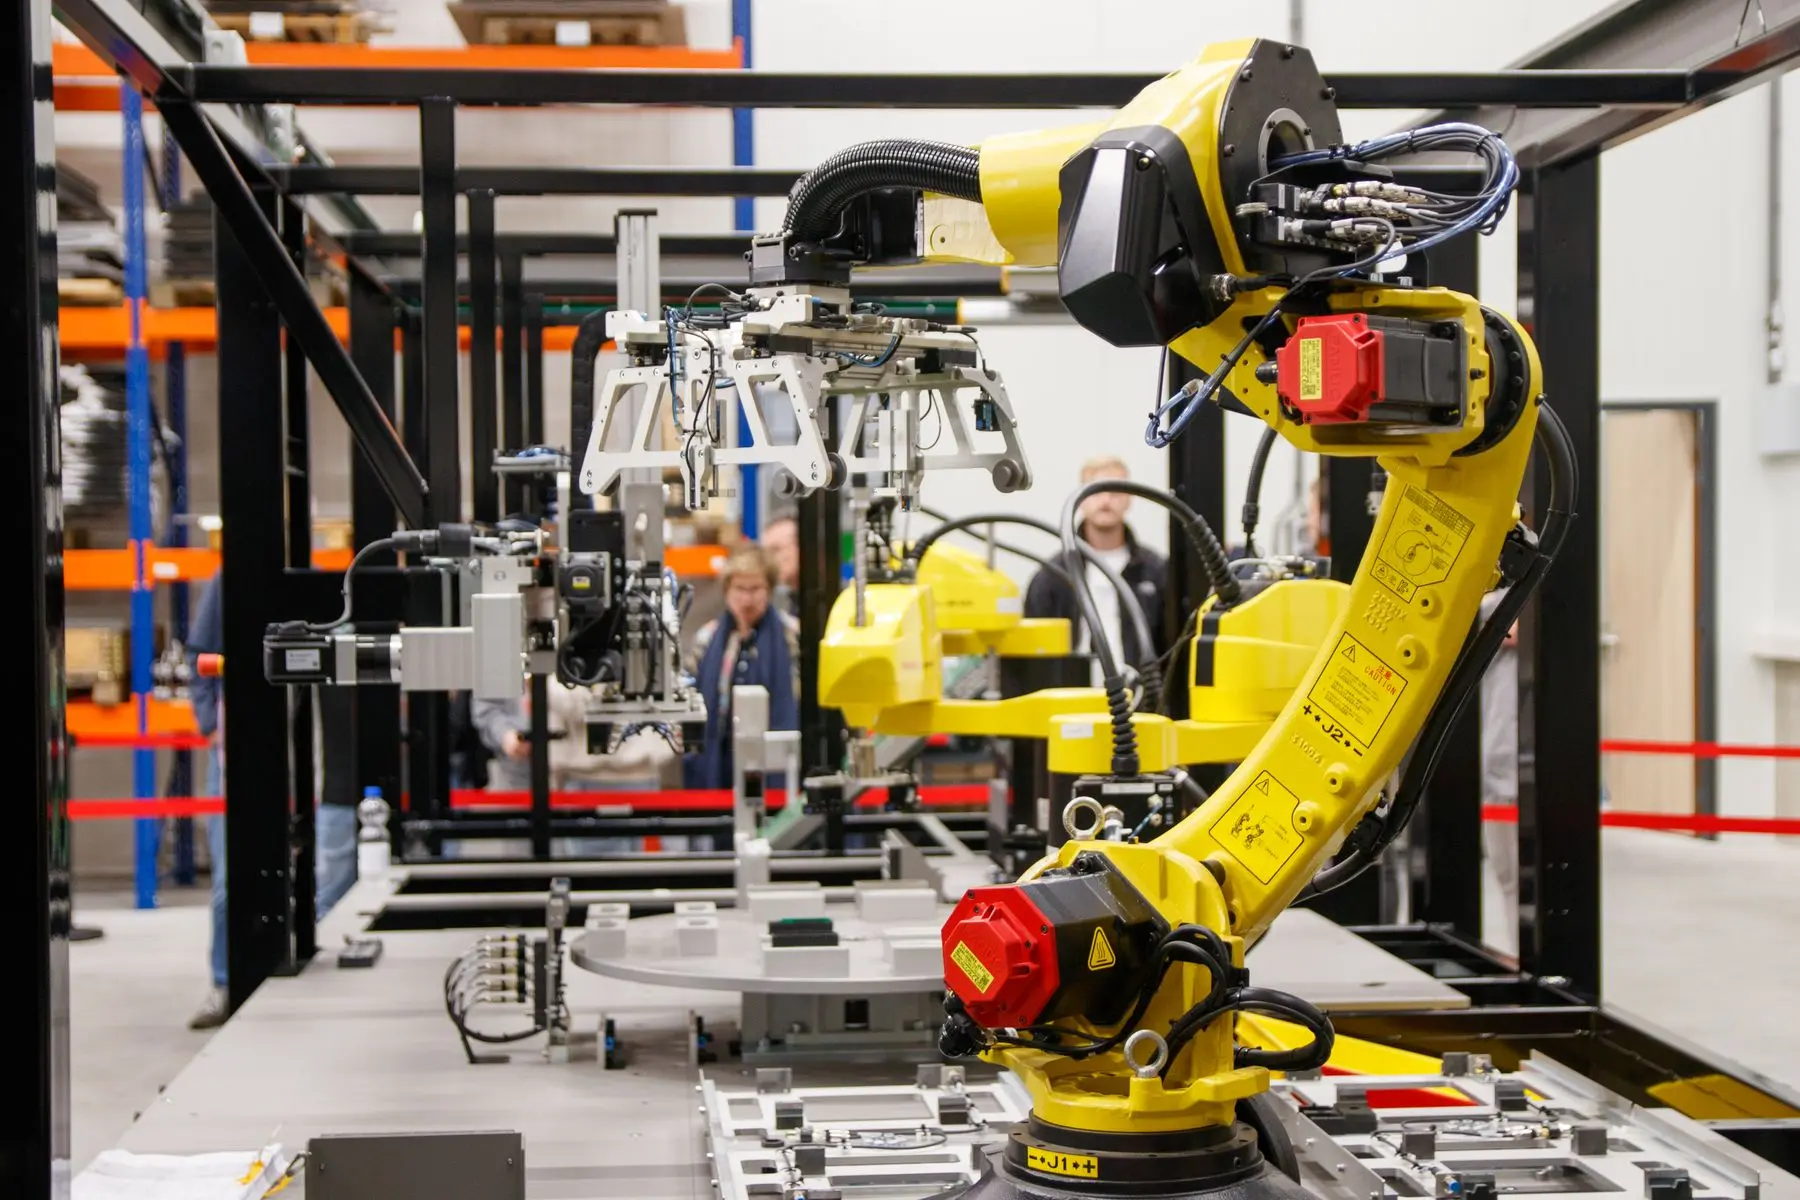
Long-reach and high-payload robot cells.
Explore heavy-duty systems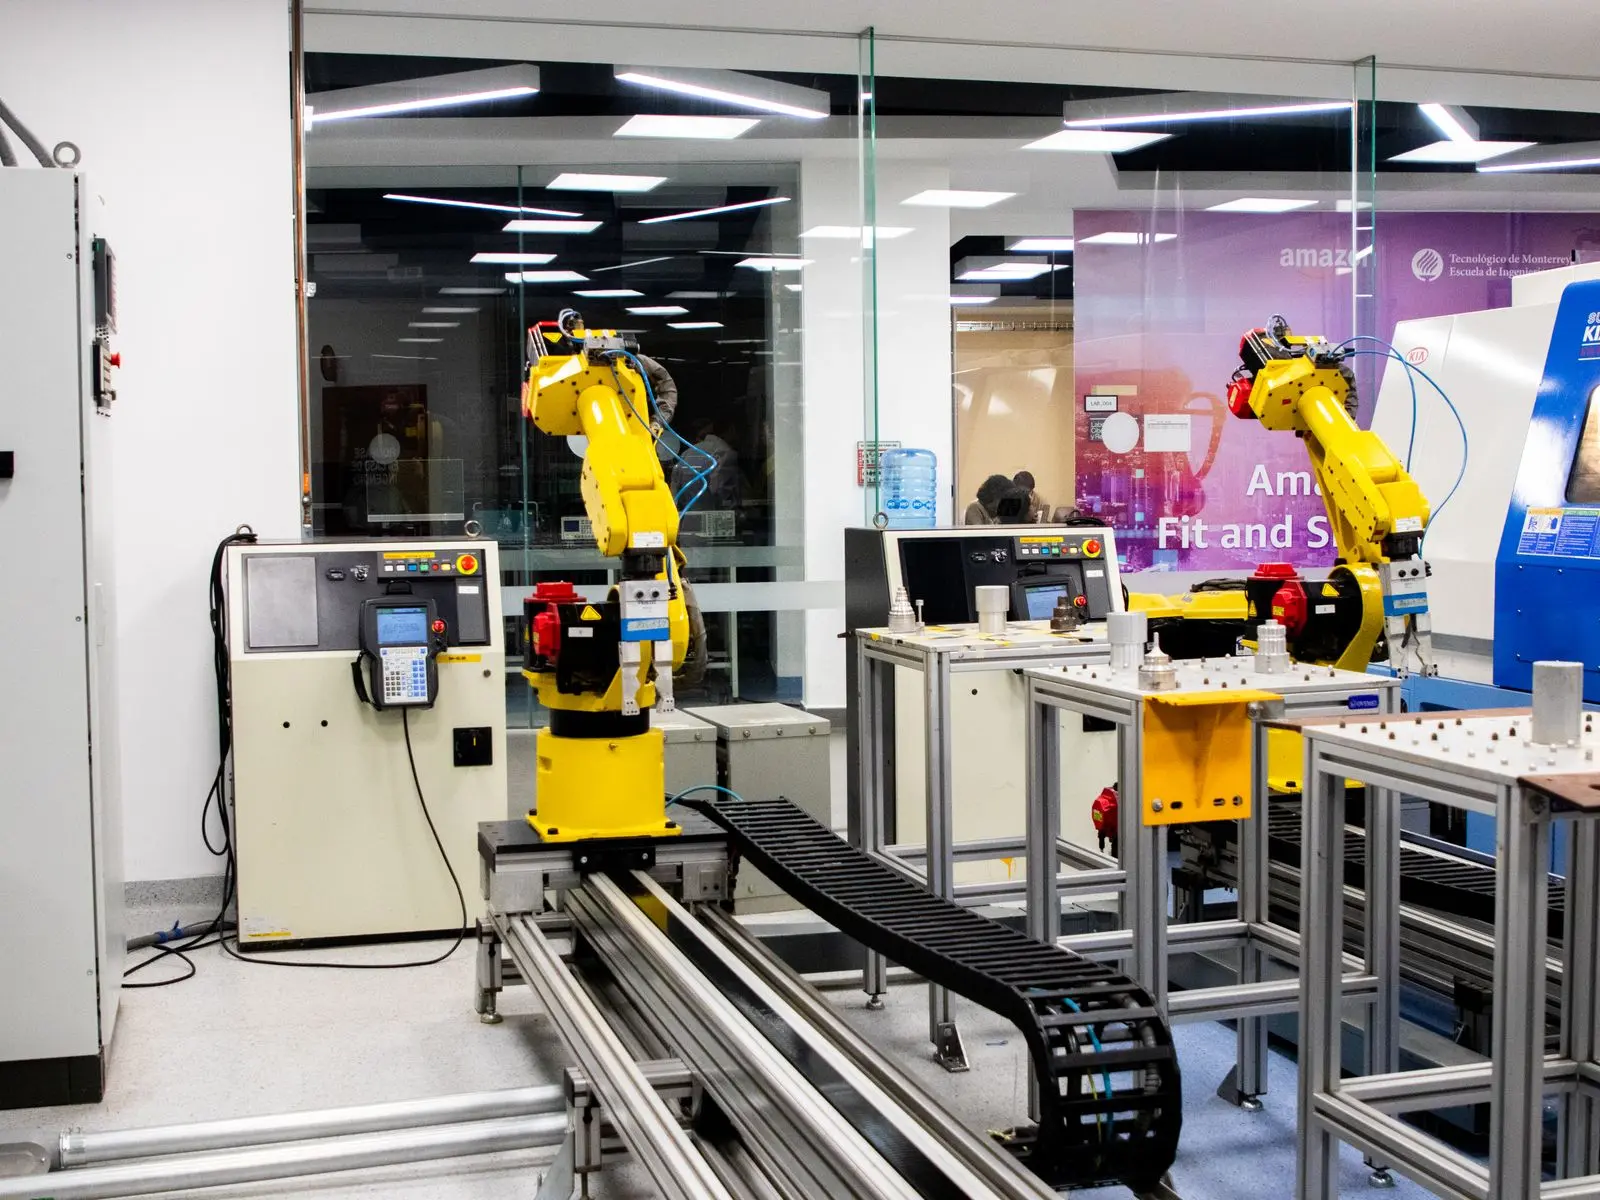
Layer recipes, changeovers and controlled operator workflows.
Explore pattern controlsRobotic palletiser quick answer
A robotic palletising system automatically picks packaged products from a production line and builds a defined load on a pallet. A complete cell combines the robot, product-specific gripper, conveyors, pallet and layer handling, pattern recipes, PLC/HMI controls, safety equipment, installation and commissioning.
More end-of-line applications
These guides answer the commercial and engineering questions manufacturers search for before requesting a palletising quotation.
Understand installed-system scope, commercial drivers and the production evidence needed for a useful budget.
Plan the business caseCompare cobot and industrial cells using products, rates, pallets, stack height, footprint and acceptance criteria.
Use the buyer checklistUnload boxes, bags and containers by product, row or layer with appropriate sensing and pallet flow.
Explore depalletisingAssess shared robots, dual pallet bays, multi-SKU routing, buffers and automatic pallet exchange.
Explore multi-line cellsOne complete palletising cell
Get one coordinated solution for product infeed, gripping, pallet handling, pattern control and safeguarding—with clear responsibility from concept through commissioning.
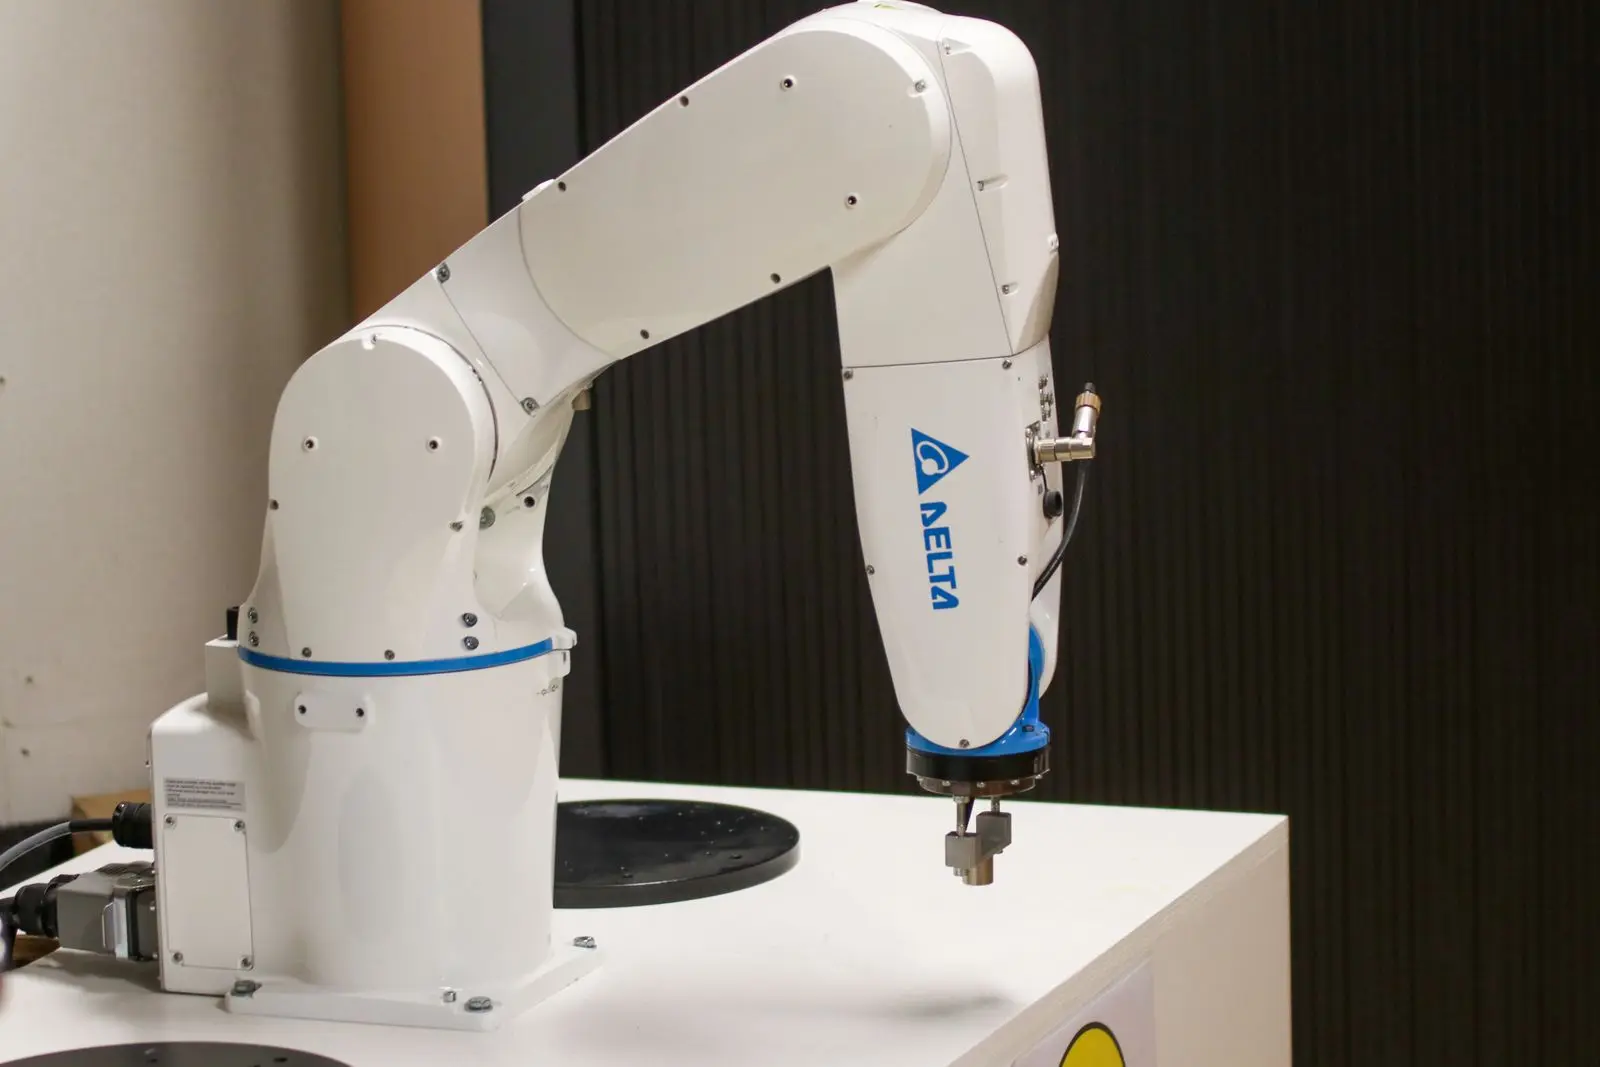

Representative robot platforms
These Oxford Industrial Automation reference platforms illustrate the available palletising range. Final selection and performance are confirmed only after the complete moving payload, cell geometry, cycle and environment have been assessed.
Representative option for high-layer palletising, depalletising and handling.

Representative option for boxes, bags, containers and general stacking.

Representative option for heavy bags, boxes, bottles and large work envelopes.
What the system can include
Conveyors, stops, guides, turners, grouping and controlled product presentation.
Vacuum, clamp, fork, support or hybrid grippers with sensors and service routing.
Pallet dispensers, location, centring, full-pallet conveyor and forklift interfaces.
Tier sheets, slip sheets, trays or top frames with magazines and pick confirmation.
Product and pallet formats, layer geometry, placement sequence and controlled changeover.
Line control, status, alarms, recipe selection, permissions and recovery guidance.
Risk assessment, guarding, interlocks, scanners, emergency stops and safe operating modes.
Testing, product trials, installation, commissioning, training and acceptance evidence.
A clear project route
Share the product range, current rate, required pallet, available floor space and a short video of the line. We use that evidence to establish likely cell architecture and the questions that need resolving.
Send your application detailsProducts, output, patterns, changeovers, operators and site constraints.
Robot, tooling, product and pallet flow, controls, safety and layout.
Programming, integration, dry testing, samples and agreed acceptance checks.
Site integration, commissioning, production trials, training and support planning.
Frequently asked questions
Typical applications include boxes, cartons, trays, bags, sacks, bottles, containers and other stable packaged products. Suitability depends on dimensions, mass, surface, stability, required rate and the available gripping features.
Product dimensions and mass, output by format, pallet size and target pattern, maximum stack height, current process photos or video, available layout and upstream or downstream equipment are the best starting point.
The system scope can include the robot, end-of-arm tooling, product conveyors, pallet handling, pattern recipes, PLC and HMI controls, sensing, safeguarding, installation, commissioning and training.
Often yes. Recipe-based changeover can manage compatible product sizes, pick strategies and patterns. The feasible range and any tooling or guide-rail changes are confirmed from the complete product matrix.
The complete machine is risk assessed. Guarding, interlocked access, scanners, safe speeds, emergency stops and operating modes are selected for the actual robot, tool, product, pallet area and operator tasks.
Yes. The cell can exchange status and control signals with upstream packers and downstream conveyors, wrappers or warehouse systems. Interfaces are agreed during the controls review.
Palletising output is the accepted product leaving on completed pallets over the agreed production window. A short repeated-pick demonstration can omit the time spent on empty pallets, full-load removal, layer sheets and format changes.
For a hypothetical pattern of ten cases per layer and eight layers, one pallet holds 80 cases. At an illustrative incoming rate of 20 cases per minute, a pallet fills every four minutes while production is steady. These values are an example, not a claimed capacity or recommended pattern. Use the actual pack, load requirements and production schedule in the comparison.
If the illustrative line above continues for a 30-second pallet change, ten more cases arrive. Determine where those cases go and how the backlog is cleared. Merely providing space for ten cases does not prove continuous operation: products already in transit, spacing and the available recovery rate also matter.
A second pallet position may change the robot route, reach, guarding, replenishment work and full-load collection. Check all intended layer positions and define how the cell confirms which bay is available. Compare the complete arrangement rather than assuming another pallet outline on a drawing doubles useful capacity.
Record the accepted physical layer state when a cycle stops. Define how moved or missing cases are reconciled before resuming the pattern. Include the final pallet in a short batch and the first pallet after a format change. Use pallet flow guidance and pattern control guidance to agree the production test.
An open-top box, flexible sack or uneven pack may not provide the gripping surface assumed by a standard pick. Begin with production packs and the required pallet pattern, then compare tooling and movement as part of the complete cell.
Show the filled pack, its centre of mass, closure and surfaces that may be contacted. Include variation in board condition, bulging or product height. For open boxes, assess a support or gripping method that does not depend on an absent lid, and define the acceptable effect on the contents.
A secure stationary grip does not establish a successful moving cycle. Trial pick, lift, transfer and placement with representative packs, including the least stable orientation. Account for gripper and service mass in the moving payload, and confirm access to all positions in the agreed layer pattern.
Define pallet location, pattern, label-facing rules and any sheets or pads. Review the completed load through removal and onward handling. Include empty-pallet replenishment and full-load exchange when comparing accepted output; a rapid repeated pick into one convenient position is not a complete production test.
Agree the response to a missed pick, moved case, interrupted layer and unavailable pallet position. Identify how the operator verifies the physical state before the cell resumes. Retain the accepted tooling, pattern recipes and sample pack references so later SKU changes can be reviewed against the demonstrated duty.
Start with the application
Send the packaged-product dimensions and mass, current line rate, required pallet pattern, available space and a photo or video of the end of the line. We will identify the next technical step.
Planning a palletising project?
Send the product dimensions and weight, target output, pallet size and a photo or short video. We will review the application and identify the next technical step.